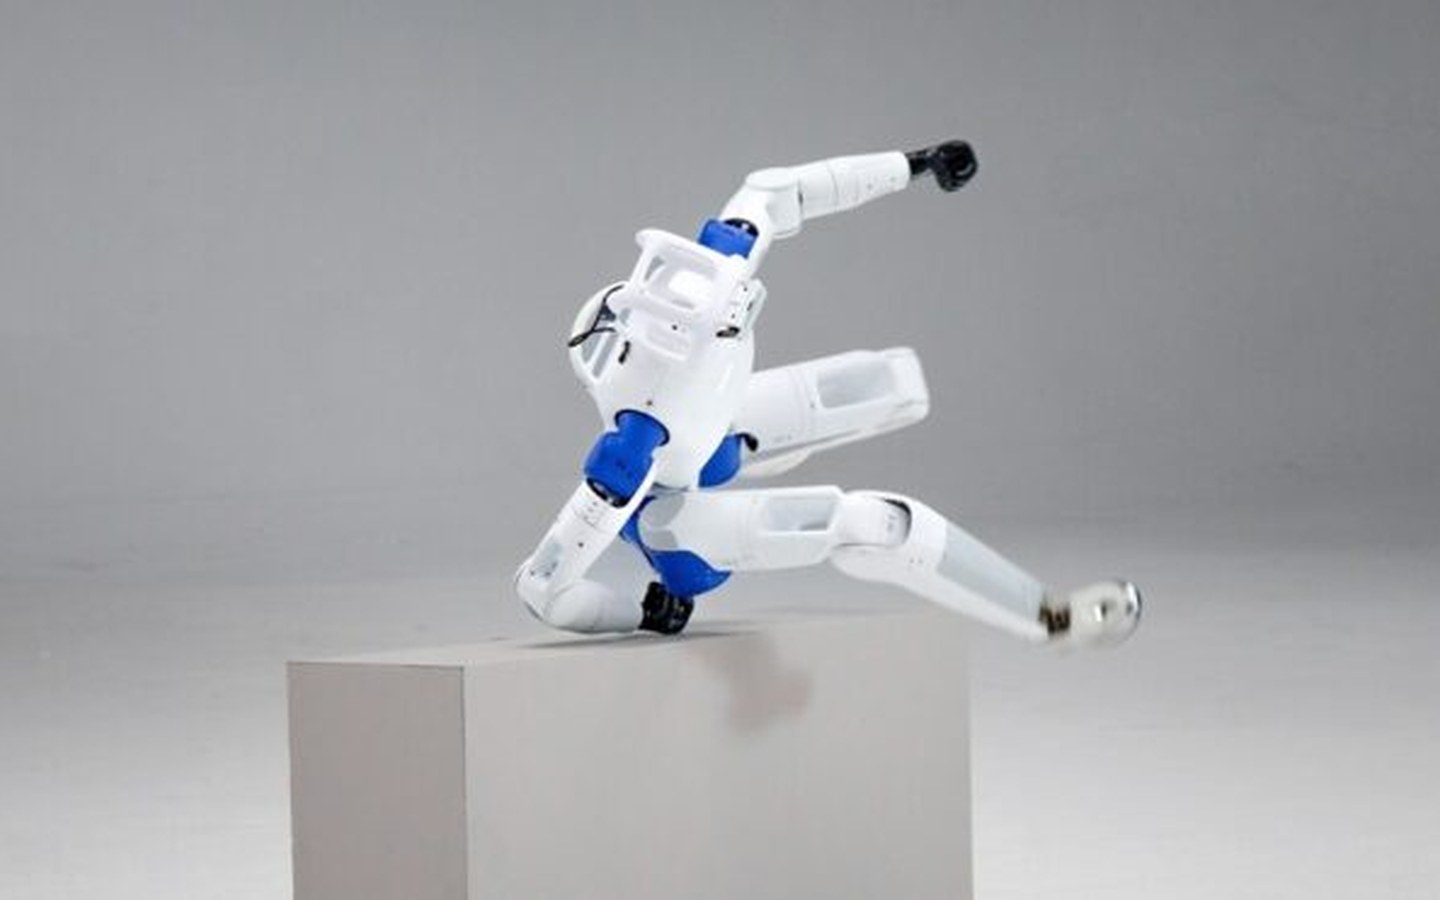
RoboParty has launched RP1, a full-stack open-source humanoid robot for embodied AI research, in a standard 24 degree-of-freedom version and a 30 degree-of-freedom Pro version.
RP1’s open toolchain spans data collection, training in simulation and deployment on the physical humanoid robot, allowing researchers to carry their own embodied AI algorithms from simulation through to experimental validation on real hardware.
Open-source humanoid robots such as RP1 could bring embodied AI research within reach of smaller university labs that cannot build a robot from scratch.
November 2, 2026 – RoboParty , a developer of humanoid robot hardware, motion-control technologies, robotics software and open development tools, has recently announced the launch of RP1 (ROBOTO 01), a full-stack open-source humanoid robot.
According to the company, RP1 is designed for advanced robotics research and embodied AI development. With open access to both hardware and software, the robot enables researchers to customize the system, integrate their own algorithms, and test new approaches on real hardware.
RoboParty stated that RP1 already supports foundational motor capabilities, including continuous walking, recovery from external disturbances, getting back up after a fall and human motion tracking. The company added that these capabilities provide a foundation for embodied AI model development and reduce the need for teams to repeatedly develop low-level motor skills.
RP1 provides whole-body control (WBC), which coordinates the arms, torso and legs to support dynamic motion tracking and posture adjustment, along with supporting tools for virtual reality (VR) teleoperation, data collection and playback, and motion retargeting. According to RoboParty, RP1 is integrated with its in-house-developed PartyOS embodied AI system, the UFO unsupervised reinforcement learning framework and MimicLite motion imitation technology, and supports motor skill learning, control policy development and higher-level applications. RP1 also provides an open toolchain that spans data collection, training in simulation, deployment on physical robots and experimental validation, according to the company.
RoboParty noted that the standard RP1 stands approximately 1.3 meters tall and features 24 actuated degrees of freedom (DoF), supporting research into gait, balance control and sim-to-real transfer. The Pro version features 30 actuated DoF, including a 2-DoF neck and two 7-DoF arms, supporting research into end-to-end policies, human-robot interaction and data collection for embodied AI. These DoF counts exclude the robot’s dexterous hands. Interchangeable head modules and wrist end effectors support multiple configurations, including the company’s in-house-developed RP Hand dexterous hand.